h3ct0rdcc/ros2_dev
ROS 2 Humble, Jazzy and Lyrical dev images: browser desktop, VS Code, Zenoh. amd64 + arm64
4.8K
h3ct0rdcc/ros2_dev repository overview
ROS 2 development images
Ready-to-use ROS 2 environments for Humble, Jazzy and Lyrical, on amd64 and arm64:
- a desktop in your browser;
- VS Code devcontainers and code-server;
- SSH and Zenoh;
- support for rootless Docker.
Source, setup script and documentation: github.com/h3ct0r/ros2_devcontainer_docker_compose
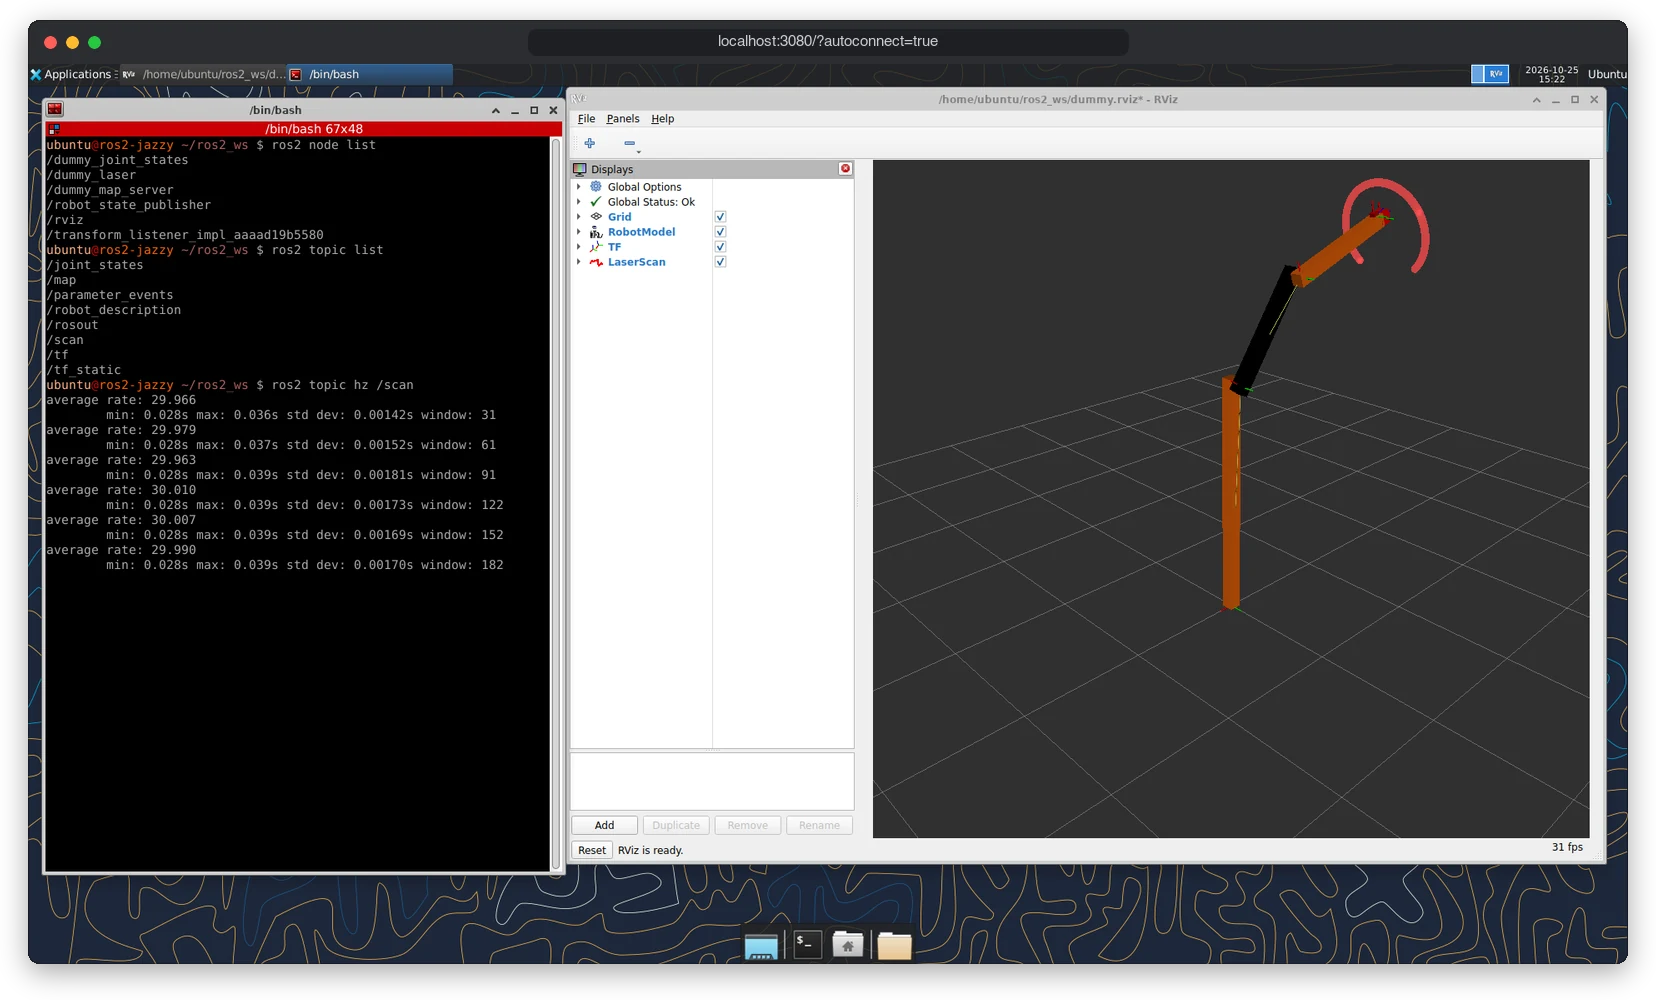
Quick start
The repo's dev.sh detects your host (macOS, Linux, NVIDIA, rootless Docker) and starts the right container:
git clone https://github.com/h3ct0r/ros2_devcontainer_docker_compose.git
cd ros2_devcontainer_docker_compose
./dev.sh up
Then open http://localhost:3080/?autoconnect=true for the desktop, or http://localhost:3081 for code-server.
To run an image directly:
docker run -d --name ros2 -p 3080:3080 -p 3081:3081 -p 3022:3022 --shm-size 1g h3ct0rdcc/ros2_dev:jazzy-desktop
Tags
<distro>-<target>, for example jazzy-desktop. Every tag is multi-arch (amd64 + arm64).
| Target | Adds |
|---|---|
base | ROS 2 base, build and debug tools, SSH, Zenoh, Python venv |
robot | perception, Nav2, SLAM Toolbox, robot_localization, RealSense, Livox, Dynamixel, CAN |
desktop | rviz2, rqt, XFCE desktop over noVNC, code-server |
full | desktop-full, Gazebo (ros_gz), MuJoCo, TurtleBot3 |
| Distro | Ubuntu | Tags |
|---|---|---|
| Humble | 22.04 | humble-base, humble-robot, humble-desktop, humble-full (= humble) |
| Jazzy | 24.04 | jazzy-base, jazzy-robot, jazzy-desktop, jazzy-full (= jazzy, latest) |
| Lyrical | 26.04 | lyrical-base, lyrical-robot, lyrical-desktop, lyrical-full (= lyrical) |
The same images are on ghcr.io/h3ct0r/ros2_dev.
Services
| Port | Service | Targets |
|---|---|---|
| 3080 | desktop in the browser (noVNC) | desktop, full |
| 3081 | code-server | desktop, full |
| 3022 | SSH (user ubuntu, password from DEV_PASSWORD, default ubuntu) | all |
| 7447 | Zenoh, with ROS_TRANSPORT=zenoh or bridge | all |
The desktop and code-server have no password unless VNC_PASSWORD and CODE_SERVER_PASSWORD are set.
Documentation
- Getting started
- Configuration
- Networking and Zenoh
- Running on a robot
- Hosts and hardware
- Images
License: MIT.
Tag summary
Content type
Image
Digest
sha256:b4893e85c…
Size
2.5 GB
Last updated
1 day ago
docker pull h3ct0rdcc/ros2_dev