palroboticssl/tiago_tutorials
Contains the docker for the TIAGo public simulation
4.2K
palroboticssl/tiago_tutorials repository overview
TIAGo Robot
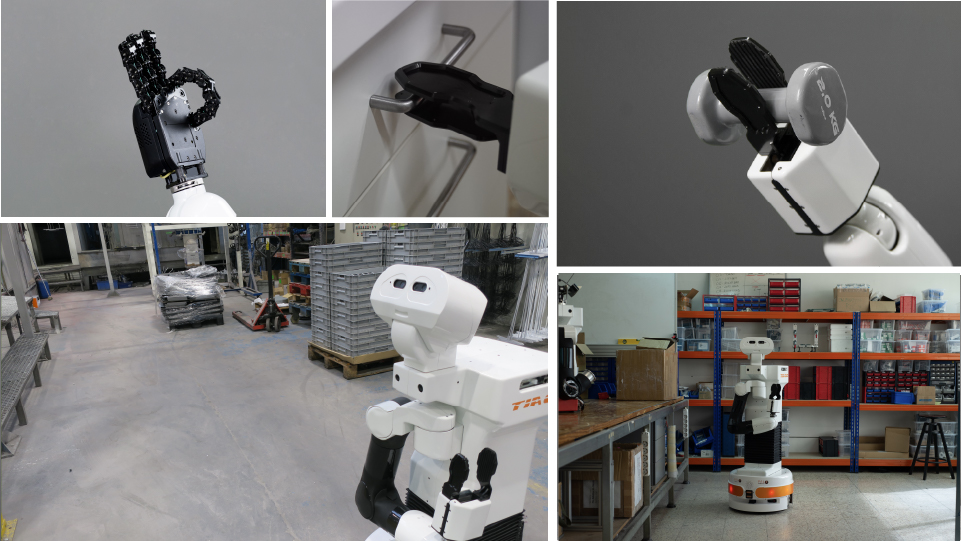
TIAGo is a service robot designed to work in indoor environments. TIAGo’s features make it the ideal platform for research, especially on ambient assisted living or light industry. It combines mobility, perception, manipulation and human-robot interaction capabilities for one specific goal: to be able to assist in research.
For technical questions regarding the public simulation of the robot please write to [email protected].
If you wish to know more or request a quote, please send us a message or refer to the product microsite.
Galery

Supported tags and respective Dockerfile links
Quick reference
- Repository: https://github.com/pal-robotics/tiago_tutorials
- Bugtracker: https://github.com/pal-robotics/tiago_tutorials/issues
Tutorials
A comprehensive set of tutorials are now available for the TIAGo robot in TIAGo Tutorials. The tutorials make use of the Gazebo simulator and currently contains tutorials on how to use OpenCV, PCL, autonomous navigation, MoveIt! and Human Robot Interaction.
Tag summary
Content type
Image
Digest
sha256:360e20970…
Size
1.5 GB
Last updated
over 3 years ago
docker pull palroboticssl/tiago_tutorials:melodic