qihaoliu/orbslam2-docker repository overview
ORB_SLAM2 Docker Image
Authors: Qihao LIU (Engineer 2A at CentraleSupelec in France)
30 May 2020: ORB_SLAM2 based on Ubuntu 16.04

- Provide ORB_SLAM2 operating environment and source code;
- All routines have been compiled;
- Provides VNC visualization interface in Desktop or ubuntu-vnc-desktop to access a Ubuntu 16.04 desktop environment.
Quick Start

Get image
Pull the image from DockerHub:
docker pull qihaoliu/orbslam2-docker:v1.0

Or use Dockerfile to build locally
git clone --branch v1.0 https://github.com/buaalqh/orbslam-docker.git
cd ./orbslam-docker
docker build -t qihaoliu/orbslam2-docker:v1.0 .
Run the docker container
Download Dataset
This ORB_SLAM2 routine provides a demonstration program for the KITTI odometry Dataset. Here, using sequence 04 in data_odometry_gray.
Create container
Execute the following command to instantiate the container:
docker run -it --rm -v YOUR_PATH_TO_KITTI/sequences/04:/root/Dataset/04 -p 5900:5900 qihaoliu/orbslam2-docker:v1.0
Connect VNC Desktop port 5900 to host:
Then open VNC Viewer Desktop and use adress localhost:5900 to connect. And in this image, the access is free (no password) as default.
(Note: docker toolbox in wins, the adress of localhost is a special adress assigned to your docker VM, ex: http://192.168.xx.xx:5900/)

Pangolin routines
cd /slam/orbslam2/ORB_SLAM2
./Examples/Stereo/stereo_kitti Vocabulary/ORBvoc.txt Examples/Stereo/KITTI04-12.yaml /root/Dataset/04

End
ORB-SLAM2
Authors: Raul Mur-Artal, Juan D. Tardos, J. M. M. Montiel and Dorian Galvez-Lopez (DBoW2)
13 Jan 2017: OpenCV 3 and Eigen 3.3 are now supported.
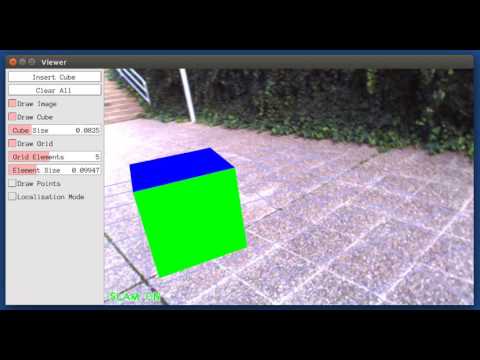
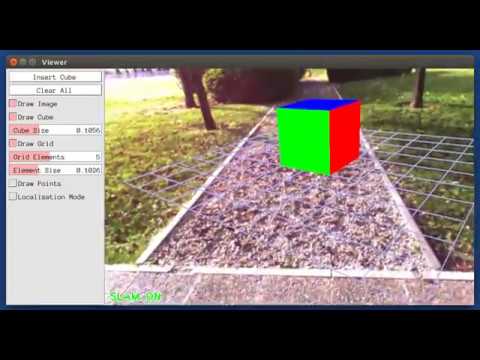
22 Dec 2016: Added AR demo (see section 7).
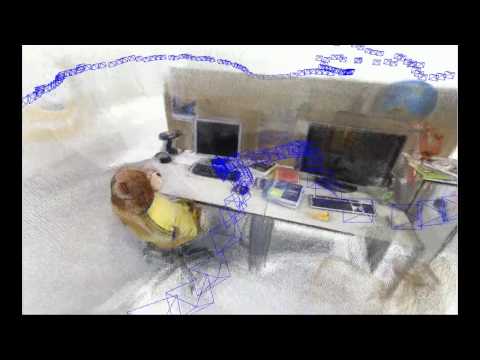
ORB-SLAM2 is a real-time SLAM library for Monocular, Stereo and RGB-D cameras that computes the camera trajectory and a sparse 3D reconstruction (in the stereo and RGB-D case with true scale). It is able to detect loops and relocalize the camera in real time. We provide examples to run the SLAM system in the KITTI dataset as stereo or monocular, in the TUM dataset as RGB-D or monocular, and in the EuRoC dataset as stereo or monocular. We also provide a ROS node to process live monocular, stereo or RGB-D streams. The library can be compiled without ROS. ORB-SLAM2 provides a GUI to change between a SLAM Mode and Localization Mode, see section 9 of this document.
Related Publications:
[Monocular] Raúl Mur-Artal, J. M. M. Montiel and Juan D. Tardós. ORB-SLAM: A Versatile and Accurate Monocular SLAM System. IEEE Transactions on Robotics, vol. 31, no. 5, pp. 1147-1163, 2015. (2015 IEEE Transactions on Robotics Best Paper Award). PDF.
[Stereo and RGB-D] Raúl Mur-Artal and Juan D. Tardós. ORB-SLAM2: an Open-Source SLAM System for Monocular, Stereo and RGB-D Cameras. IEEE Transactions on Robotics, vol. 33, no. 5, pp. 1255-1262, 2017. PDF.
[DBoW2 Place Recognizer] Dorian Gálvez-López and Juan D. Tardós. Bags of Binary Words for Fast Place Recognition in Image Sequences. IEEE Transactions on Robotics, vol. 28, no. 5, pp. 1188-1197, 2012. PDF
1. License
ORB-SLAM2 is released under a GPLv3 license. For a list of all code/library dependencies (and associated licenses), please see Dependencies.md.
For a closed-source version of ORB-SLAM2 for commercial purposes, please contact the authors: orbslam (at) unizar (dot) es.
If you use ORB-SLAM2 (Monocular) in an academic work, please cite:
@article{murTRO2015,
  title={{ORB-SLAM}: a Versatile and Accurate Monocular {SLAM} System},
  author={Mur-Artal, Ra\'ul, Montiel, J. M. M. and Tard\'os, Juan D.},
  journal={IEEE Transactions on Robotics},
  volume={31},
  number={5},
  pages={1147--1163},
  doi = {10.1109/TRO.2015.2463671},
  year={2015}
 }
if you use ORB-SLAM2 (Stereo or RGB-D) in an academic work, please cite:
@article{murORB2,
  title={{ORB-SLAM2}: an Open-Source {SLAM} System for Monocular, Stereo and {RGB-D} Cameras},
  author={Mur-Artal, Ra\'ul and Tard\'os, Juan D.},
  journal={IEEE Transactions on Robotics},
  volume={33},
  number={5},
  pages={1255--1262},
  doi = {10.1109/TRO.2017.2705103},
  year={2017}
 }
Tag summary
Content type
Image
Digest
Size
1.3 GB
Last updated
over 6 years ago
docker pull qihaoliu/orbslam2-docker:v1.0